Loading...
Searching...
No Matches
org.wpilib.command3.BindingScope Interface Reference
Inheritance diagram for org.wpilib.command3.BindingScope:
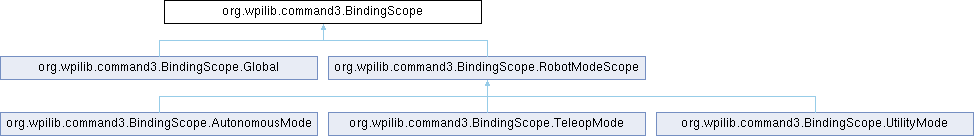
Classes | |
| class | Global |
| interface | RobotModeScope |
| class | AutonomousMode |
| class | TeleopMode |
| class | UtilityMode |
Public Member Functions | |
| boolean | active () |
| record | ForCommand (Scheduler scheduler, Command command) implements BindingScope |
| record | ForOpmode (long opmodeId) implements BindingScope |
Static Public Member Functions | |
| static BindingScope | createNarrowestScope (Scheduler scheduler) |
Detailed Description
A scope for when a binding is live. Bindings tied to a scope must be deleted when the scope becomes inactive.
Definition at line 14 of file BindingScope.java.
Member Function Documentation
◆ active()
| boolean org.wpilib.command3.BindingScope.active | ( | ) |
Checks if the scope is active. Bindings for inactive scopes are removed from the scheduler.
- Returns
- True if the scope is still active, false if not.
Implemented in org.wpilib.command3.BindingScope.AutonomousMode, org.wpilib.command3.BindingScope.Global, org.wpilib.command3.BindingScope.TeleopMode, and org.wpilib.command3.BindingScope.UtilityMode.
◆ createNarrowestScope()
|
static |
Creates the narrowest binding scope available based on the current state of the scheduler and selected opmode.
- Parameters
-
scheduler The scheduler to create the binding scope for.
- Returns
- The narrowest binding scope available.
Definition at line 29 of file BindingScope.java.
◆ ForCommand()
A binding scoped to the lifetime of a specific command. This should be used when a binding is created within a command, tying the lifetime of the binding to the declaring command.
- Parameters
-
scheduler The scheduler managing the command. command The command being scoped to.
Definition at line 73 of file BindingScope.java.
◆ ForOpmode()
| record org.wpilib.command3.BindingScope.ForOpmode | ( | long | opmodeId | ) |
A binding scoped to a running opmode.
- Parameters
-
opmodeId The ID of the opmode that the binding is scoped to.
Definition at line 85 of file BindingScope.java.
The documentation for this interface was generated from the following file:
- org/wpilib/command3/BindingScope.java
